Choosing the right stepper motor requires a clear understanding of its construction, winding arrangement, and control requirements. Although these motors share the same basic purpose, their internal designs can produce noticeably different performance in an automation system.
For that reason, engineers should look beyond motor size and rated voltage when selecting a solution. Torque requirements, step angle, winding configuration, driver compatibility, and operating conditions all influence the final choice.
This guide focuses on the practical details behind stepper motor types, wiring configurations, and microstepping. By understanding these areas, automation professionals can make better decisions when designing or upgrading motion-control equipment.
Understanding Stepper Motor Types
Manufacturers commonly produce three main stepper motor types: permanent magnet, variable reluctance, and hybrid. Each design uses a different rotor construction, which affects its operating characteristics.
Permanent Magnet Stepper Motors
Permanent magnet stepper motors use a magnetized rotor and energized stator windings. The magnetic interaction between these components creates controlled angular movement.
This design suits applications that need straightforward positioning and moderate torque. Manufacturers often use permanent magnet designs in compact equipment, instruments, and light-duty automation systems.
However, engineers should check the required speed and load before selecting this design. A motor that works well at low speed may not deliver the required performance under a heavier or faster load.
Variable Reluctance Stepper Motors
Variable reluctance stepper motors use a toothed soft-iron rotor instead of a permanent magnet rotor. When the driver energizes a stator winding, the rotor moves toward the position that offers the lowest magnetic reluctance.
This construction provides a simple rotor design and can support rapid movement in suitable applications. Nevertheless, the motor has different torque characteristics from permanent magnet and hybrid designs.
Therefore, engineers should evaluate the application's speed, load, and positioning requirements before choosing a variable reluctance motor.
Hybrid Stepper Motors
Hybrid stepper motors combine a permanent magnet rotor with a toothed rotor structure. This arrangement provides precise stepping and useful torque across many industrial applications.
As a result, hybrid designs have become common in CNC equipment, packaging machinery, robotics, laboratory equipment, and automated positioning systems.
Their popularity comes from their balance of precision, torque, and control flexibility. Still, the correct motor size and driver remain essential for dependable operation.
Step Angle and Positioning Resolution
Step angle determines how far the motor shaft moves during one full step. Smaller step angles allow the motor to make finer movements during full-step operation.
For example, a motor with a 1.8-degree step angle makes 200 full steps during one complete revolution. A 0.9-degree motor requires 400 full steps for the same revolution.
However, step angle alone does not determine the final positioning performance of a machine. Mechanical backlash, load conditions, acceleration, driver settings, and system design can also affect actual positioning results.
Therefore, engineers should consider the complete motion system instead of selecting a motor based only on its step angle.
Choosing the Right Motor Construction
The correct choice among stepper motor types depends on the machine's requirements.
A compact application with moderate movement demands may suit a permanent magnet design. On the other hand, a system requiring stronger positioning performance may use a hybrid motor.
In addition, available installation space, required torque, operating speed, electrical specifications, and driver compatibility should all influence the selection.
Most importantly, engineers should match the motor to the actual mechanical load. An oversized motor can increase system cost, while an undersized motor may struggle during acceleration or lose position under demanding conditions.
Why Wiring Configuration Matters
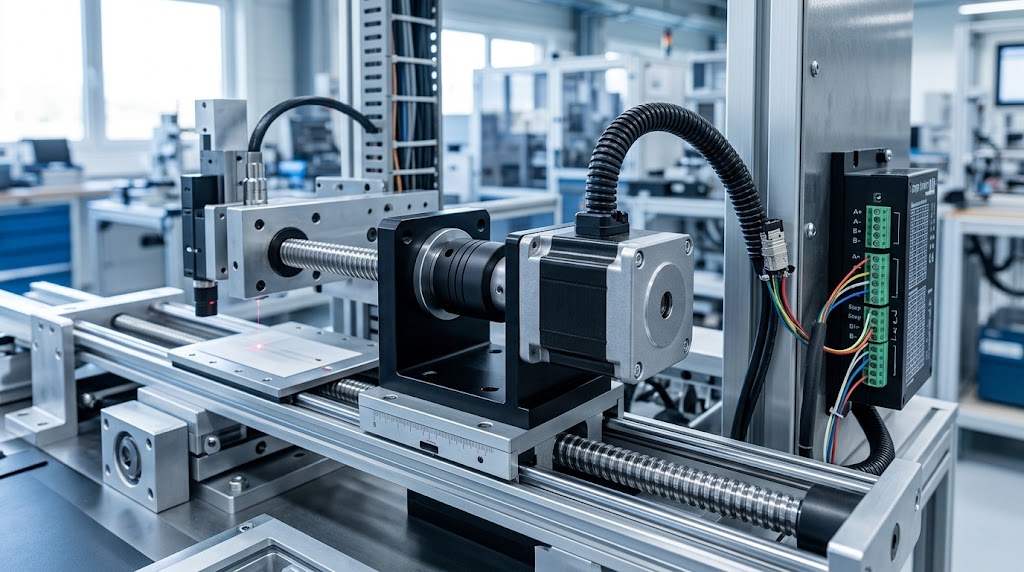
Motor wiring directly affects how a stepper motor connects to its driver. Common motors use four, six, or eight leads, and each configuration provides different connection possibilities.
A four-lead motor normally uses two winding pairs. The driver controls current through these windings to produce the required shaft movement.
Six-lead and eight-lead motors provide additional wiring options. Depending on the motor design, engineers may connect windings in series or parallel to achieve different electrical characteristics.
Consequently, the wiring configuration can influence current requirements, torque behavior, and overall motor performance.
Always follow the manufacturer's wiring diagram before connecting a motor to a driver. Correct identification of each winding prevents connection errors and helps the system operate within its intended electrical limits.
Planning the Wiring Before Installation
Before installation, identify the motor's winding pairs with the manufacturer's documentation or an appropriate electrical test method. Then verify the driver's rated current and voltage requirements.
After that, confirm that the selected connection matches the motor manufacturer's recommended configuration.
This preparation can prevent unnecessary troubleshooting later. It also helps ensure that the driver supplies the correct current to each winding.
Stepper Motor Types and Wiring Configurations
Understanding wiring configurations is essential when working with different stepper motor types. The number of motor leads determines how engineers can connect the windings to a suitable driver.
Most industrial stepper motors use four, six, or eight leads. Each configuration offers different connection options, so the wiring method should always match the motor's internal winding arrangement and the driver's specifications.
4-Wire Stepper Motor Types and Wiring
A four-wire stepper motor normally contains two independent winding pairs. Each pair connects to one output channel on a bipolar stepper motor driver.
The driver controls current through both windings and changes the current direction according to the required stepping sequence. Consequently, correct identification of the two winding pairs remains important before powering the system.
Engineers can usually identify each pair by checking the manufacturer's wiring diagram. If documentation is unavailable, an appropriate resistance measurement can help identify which wires belong to the same winding.
However, engineers should never guess the connection by repeatedly applying power. An incorrect connection can produce vibration, poor torque, or excessive electrical stress.
6-Wire Stepper Motor Types and Wiring
Six-wire motors provide a center tap for each winding. This configuration gives engineers more flexibility when connecting the motor to a compatible driver.
Depending on the driver and application, engineers may use the full winding or a portion of each winding. However, the selected configuration changes the electrical characteristics of the motor.
Therefore, the manufacturer's specifications should guide the final connection. The driver must also support the selected arrangement and remain within the motor's rated current limits.
8-Wire Stepper Motor Types and Wiring
Eight-wire stepper motors provide separate access to their winding sections. As a result, engineers can configure these motors in different ways depending on the required electrical performance.
Series connections can provide higher inductance, while parallel connections can support different current and performance characteristics. Consequently, the wiring choice can influence how the motor behaves at different speeds.
For industrial equipment, engineers should select the configuration according to the motor datasheet rather than relying on a general wiring rule.
Bipolar and Unipolar Stepper Motor Connections
Stepper motor systems can use bipolar or unipolar control methods. The main difference comes from how the driver manages current through the motor windings.
A bipolar driver reverses current through each winding. Because of this approach, it can use the winding more fully and commonly pairs with four-wire motors.
A unipolar arrangement uses winding center taps to simplify current switching. However, modern industrial motion systems frequently use bipolar drivers because they provide flexible control and work with several common motor configurations.
Therefore, when selecting among stepper motor types, engineers should consider driver architecture at the same time. Motor and driver compatibility directly affects the available performance.
Choosing a Driver for Stepper Motor Types
The motor itself represents only one part of a motion-control system. A suitable driver must match the motor's electrical requirements and provide the desired control functions.
First, check the motor's rated current. Then compare that value with the driver's adjustable output range. Additionally, verify the driver's supply-voltage range and supported control signals.
The driver should also provide sufficient current regulation for the intended application. Moreover, features such as overcurrent protection, thermal protection, and fault reporting can improve system reliability.
For demanding automation equipment, engineers should also consider acceleration requirements and the operating speed range. A driver that works well at low speed may not provide the same results at higher speeds.
What Is Microstepping?
Microstepping divides a motor's full step into smaller electrical increments. Instead of moving directly from one full-step position to another, the driver regulates winding currents to create intermediate positions.
For example, a driver configured for 16 microsteps can divide one full motor step into 16 smaller command increments.
As a result, microstepping can produce smoother shaft movement and reduce noticeable vibration. It can also improve the motion resolution available to the control system.
However, microstepping does not automatically guarantee proportional mechanical positioning accuracy. Mechanical load, resonance, friction, motor construction, and control quality can all influence the final result.
Microstepping Settings and Motion Quality
Different drivers offer different microstepping settings, such as half-step, 1/4-step, 1/8-step, and 1/16-step operation. Some advanced drivers provide even finer settings.
Higher microstepping generally creates smoother movement. Nevertheless, increasing the setting indefinitely does not always provide a practical benefit.
For example, an application that already operates smoothly at 1/8-step may gain little from moving to an extremely high microstep setting. Therefore, engineers should select a setting that balances smoothness, control resolution, speed, and system requirements.
Moreover, the controller must generate the required pulse frequency. Higher microstep settings require more command pulses for the same shaft speed. Consequently, the controller and communication system must handle the increased pulse rate.
Microstepping in Industrial Automation
Microstepping can benefit applications that require smooth and controlled movement. CNC equipment, laboratory systems, inspection machines, packaging equipment, and positioning mechanisms can all use microstepping when the application supports it.
In addition, smoother movement can reduce mechanical vibration in suitable systems. This can help improve the behavior of equipment that handles delicate or precision-sensitive processes.
However, engineers should treat microstepping as one part of the overall motion strategy. Proper motor sizing, acceleration control, mechanical design, and driver configuration remain equally important.
Practical Selection Tips for Stepper Motor Types
Selecting the right stepper motor types starts with the machine's actual requirements. Instead of choosing a motor based only on its physical size, engineers should evaluate torque, speed, step angle, winding configuration, and available space.
Next, calculate the load requirements and consider acceleration. The motor needs enough torque to move the load without losing synchronization during demanding movements.
Additionally, check the motor's current rating and select a compatible driver. The power supply should also meet the driver's requirements while providing enough capacity for the complete system.
Finally, consider the operating environment. Temperature, dust, vibration, installation space, and duty cycle can all influence the suitable motor and driver combination.
Common Wiring Mistakes with Stepper Motor Types
Incorrect winding identification remains one of the most common wiring problems. Connecting wires from different windings can prevent the motor from producing normal rotation.
Another mistake involves ignoring the driver's current setting. Excessive current can increase motor temperature, while insufficient current can reduce available torque.
Furthermore, loose terminals and poor cable routing can introduce intermittent faults. Therefore, secure connections and appropriate industrial wiring practices matter just as much as selecting the correct motor.
Before commissioning the system, verify every connection against the motor and driver documentation. Then test the motor at a controlled speed before applying the full machine load.
Frequently Asked Questions About Stepper Motor Types
What are the main stepper motor types?
The main stepper motor types include permanent magnet, variable reluctance, and hybrid designs. Each type, however, has different construction and performance characteristics.
Which Stepper Motor Types Suit Industrial Automation?
Hybrid motors often suit industrial positioning applications because they can provide useful torque and precise movement. However, engineers should always match the motor to the actual load and speed requirements.
How Many Wires Do Stepper Motors Have?
Stepper motors commonly use four, six, or eight leads. For example, four-wire motors typically provide two winding pairs, while six-wire and eight-wire designs offer additional connection options.
Can Microstepping Improve Motor Movement?
Microstepping can create smoother movement and reduce noticeable vibration. However, higher microstep settings do not automatically guarantee higher mechanical positioning accuracy.
How Should You Choose Stepper Motor Types?
Start by checking torque, speed, step angle, wiring configuration, and driver compatibility. Additionally, consider the operating environment and mechanical load. As a result, the complete machine requirements should guide the final selection.
Conclusion
Understanding different stepper motor types makes motor selection easier for industrial automation projects. Permanent magnet, variable reluctance, and hybrid designs each offer different characteristics.
Furthermore, correct wiring and driver selection play an important role in reliable operation. Microstepping can then provide smoother movement when the application benefits from finer control.
Ultimately, engineers should select the motor, driver, wiring configuration, and control settings as one complete system. This approach helps create reliable and efficient motion-control solutions for modern automation equipment.
Pingback: Stepper Motor Torque: Calculation & Selection Guide
Pingback: Stepper Motor Troubleshooting: Causes & Fixes