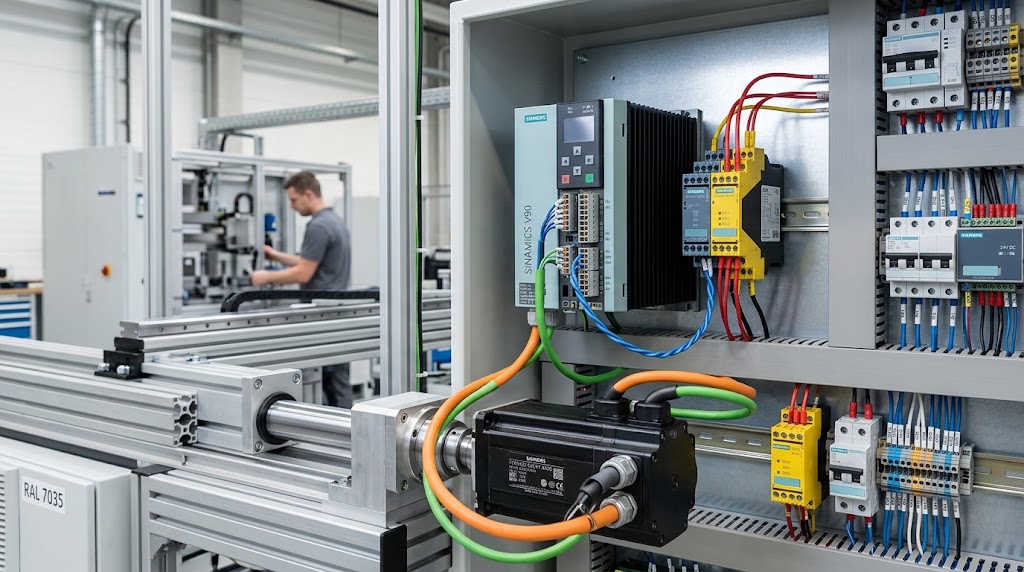
Servo motor brake control plays a critical role in industrial automation, especially when machines handle vertical loads, lifting mechanisms, or gravity-driven axes. During a sudden power failure, a vertical axis can descend because gravity continues to act on the load even after the motor loses its ability to generate torque. Therefore, engineers must coordinate an electromagnetic holding brake with Safe Torque Off (STO) to manage hazardous motion and reduce the risk of equipment damage. Furthermore, this combination helps maintain machine safety during emergency stops, drive faults, and unexpected power interruptions.
However, a holding brake and STO perform different functions. The holding brake generates mechanical friction to hold a stationary motor shaft, while STO prevents the servo drive from generating torque. Consequently, neither function replaces the other in applications that require controlled stopping and secure load retention. In addition, engineers must consider load inertia, brake response time, motor torque, and the safety requirements of the complete machine. A well-designed system coordinates these functions instead of relying on a single component to manage every stopping condition.
For example, a vertical packaging machine may use a servo motor to position a heavy carriage accurately. If the drive loses power before the brake develops sufficient holding force, the carriage may move downward. Therefore, engineers must evaluate brake timing, backup protection, and the drive manufacturer's recommended safety architecture. Moreover, a properly engineered arrangement reduces unnecessary mechanical wear while improving operational reliability.
Fundamentals of Servo Motor Brake Control in Automation
An electromagnetic holding brake typically uses a spring-applied, electrically released mechanism. When the brake receives its rated voltage, an electromagnetic field releases the friction surfaces and allows the motor shaft to rotate. Conversely, when the supply voltage disappears, springs apply the brake and generate holding force. Consequently, this design can retain a stationary load during a power interruption, provided the brake has sufficient capacity and the mechanism meets the application's requirements.
A dynamic friction brake serves a different purpose because it dissipates kinetic energy while a shaft or load moves. For instance, a machine may use a dedicated dynamic braking system to reduce motor speed during deceleration. However, engineers must distinguish mechanical friction brakes from electrical dynamic braking, which uses the motor and drive circuit to dissipate or regenerate energy. Each method handles energy differently, so engineers must select equipment according to the stopping duty, load inertia, and manufacturer's specifications.
Using a holding brake to stop a moving motor can cause excessive friction, heat, and premature lining wear. Furthermore, repeated emergency stops through a brake designed only for static holding can damage its friction surfaces and reduce its service life. Therefore, the servo drive should normally decelerate the motor through controlled torque before the holding brake engages. Nevertheless, engineers must evaluate emergency conditions separately because some faults prevent controlled deceleration.
The servo drive coordinates brake operation through dedicated parameters and digital control signals. First, the drive establishes sufficient motor torque to support the load. Next, it commands the brake to release and allows the specified release delay to expire before initiating motion. During stopping, the drive decelerates the motor and maintains the required holding torque. Finally, the drive commands brake engagement and follows its configured timing sequence. However, exact sequencing varies by manufacturer, so engineers must consult the specific drive manual rather than assume that every model uses identical logic.
Essential Hardware Needed for Servo Motor Brake Control
A reliable brake circuit requires a suitable 24 V DC power supply, an electromagnetic holding brake, an interposing relay when the drive output cannot directly handle the brake load, and appropriate inductive suppression. Furthermore, engineers must verify the brake coil's voltage, current, power consumption, and operating duty before selecting electrical components. These checks help prevent voltage drops, relay failures, and unreliable brake operation.
The 24 V DC holding brake coil converts electrical energy into magnetic force that releases the mechanical brake. When the coil receives its rated voltage, it overcomes the spring force and separates the friction surfaces. Conversely, when the supply voltage disappears, the springs apply the brake. However, the coil current and release characteristics depend on the brake design. Therefore, engineers should check the manufacturer's datasheet and measure the actual voltage at the brake terminals during operation. Long cables and undersized conductors can cause voltage drops that prevent complete brake release.
A 24 V DC interposing relay provides an interface between the servo drive's digital output and the brake power circuit. The relay allows a low-current control signal to switch a separate brake supply when the drive output cannot directly handle the coil current. In addition, suitable relay isolation can protect the drive output from electrical disturbances originating in the brake circuit. Nevertheless, engineers must confirm the digital output's sourcing or sinking arrangement, output current rating, relay coil requirements, and contact rating before completing the wiring. An incorrectly selected relay can cause contact arcing, overheating, or inconsistent switching.
An inductive suppression device protects switching components from voltage spikes that occur when a relay coil loses power. For a compatible DC relay coil, a 1N4007 diode can provide a simple flyback path for the collapsing magnetic field. Engineers connect the diode in reverse bias during normal operation, with its cathode toward the positive supply and its anode toward the negative side of the coil. Consequently, the diode limits the voltage spike when the relay switches off. However, engineers must verify the diode's current and voltage ratings against the circuit requirements.
The suppression method also affects how quickly a magnetic field collapses. For example, a standard flyback diode can extend relay release time because it allows current to decay gradually. Therefore, engineers should install the diode across the appropriate relay coil rather than automatically placing it across the motor holding-brake coil. A diode across the brake coil can delay brake engagement, which may create additional risk on a vertical axis. Instead, engineers should follow the brake manufacturer's recommended suppression method and account for its effect on the required stopping sequence.
Finally, the complete hardware arrangement must support both normal motion and fault handling. Engineers should verify supply capacity, protective grounding, conductor sizing, relay contact behavior, and cable routing before commissioning. Furthermore, they should confirm that the brake circuit and STO safety circuit perform their separate functions correctly. This approach provides a sound foundation for the detailed wiring procedures, drive parameter settings, and safety relay integration covered in Part 2.
Wiring Setup for Servo Motor Brake Control
A reliable servo motor brake control circuit coordinates the motor drive, holding brake, and 24V DC supply. However, terminal assignments and brake outputs vary by manufacturer, so always follow the specific drive and motor manuals.
First, connect the correctly rated 24V DC supply to the brake circuit’s designated positive and common terminals. Furthermore, verify the supply’s current capacity against the brake coil’s rated current and any relay-coil load.
Next, connect the servo drive’s designated brake-control digital output (DO) to the interposing relay’s control input, following the output’s voltage, current, and polarity requirements. Consequently, the relay switches the brake coil’s power without exceeding the drive output’s electrical rating.
Connect the 24V supply positive to the relay’s normally open contact supply terminal. Then, connect the relay’s switched output to the brake coil’s positive terminal and the coil’s negative terminal to the supply return, provided the component manuals specify this arrangement.
For relay-coil suppression, place a 1N4007 diode across a compatible DC relay coil, with the cathode toward positive and the anode toward negative. However, do not automatically install the same diode across the motor brake coil because suppression can delay brake engagement; use the brake manufacturer’s approved suppression method.
Finally, verify protective earthing, wire ratings, fuse protection, and terminal torque before testing. Therefore, confirm the brake engages on loss of its release supply and that the machine’s risk assessment addresses any vertical load that could fall.
Drive Parameter Configuration for Servo Motor Brake Control
Correct timing allows the drive to establish motor torque before releasing the holding brake. Furthermore, the brake sequence must prevent the brake from fighting the motor during movement or allowing a gravity-loaded axis to descend.
Brake Release Delay Time defines the interval between the drive’s brake-release command and the start of motion. Therefore, set it according to the brake’s actual release time and the drive manufacturer’s instructions so the motor can develop sufficient holding torque first.
Brake Engagement Delay Time coordinates brake application with motor deceleration or stop completion. However, an excessive delay can let a vertical axis move before the brake holds it, while an insufficient delay can make the brake engage before the motor reaches a safe state.
Zero Speed Threshold defines the speed level that the drive treats as stopped for relevant brake-sequence logic. Consequently, choose a value that suits encoder feedback, mechanical behavior, and the manufacturer’s permitted settings rather than relying on a universal number.
After configuring these parameters, test the sequence at low speed under controlled conditions. In addition, check for brake noise, unwanted axis movement, excessive heat, and repeated engagement during motion; correct any abnormal behavior before returning the machine to service.
Safe Torque Off (STO) Integration & Dual-Channel Wiring
Safe Torque Off (STO), defined under IEC 61800-5-2, prevents a drive from generating torque when its safety function activates. Furthermore, STO supports emergency-stop and other safety functions, but it does not provide electrical isolation or mechanically hold a vertical load.
A main power contactor disconnects the drive’s power supply, whereas STO disables torque generation through the drive’s safety circuitry. Consequently, STO can often stop torque more quickly and reduce contactor switching wear; however, the actual response depends on the drive, and maintenance still requires proper electrical isolation.
For dual-channel wiring, connect the emergency-stop button to a compatible safety relay according to the relay’s wiring diagram. Then, connect the relay’s two safety outputs to the drive’s designated STO1 and STO2 input channels, following the drive manual’s specified terminal arrangement.
Some drives also provide +24V and STO GND terminals for the safety-input circuit. However, these terminals do not follow one universal wiring scheme, so verify the drive’s manual before connecting the supply, common, or safety relay outputs.
External Device Monitoring (EDM) allows the safety relay to check feedback contacts from monitored devices, such as contactors. Furthermore, the relay can prevent a reset when feedback indicates that a monitored device failed to reach its required state; wire EDM according to the safety relay manufacturer’s diagram.
After wiring, test both emergency-stop channels, fault detection, reset behavior, and the drive’s STO status. Therefore, validate the complete safety function against the machine risk assessment and applicable safety requirements rather than treating a successful wiring test as proof of compliance.
Best Practices for Servo Motor Brake Control & STO Systems
Separate motor power, brake wiring, encoder cables, and safety signals where practical. Furthermore, follow manufacturer guidance for cable shielding, grounding, routing, and shield termination to reduce electrical noise and prevent intermittent faults.
Size the 24V supply, relay contacts, conductors, and protective devices for the actual loads. In addition, inspect connectors and brake wiring regularly because loose terminals, damaged insulation, and voltage drops can cause unreliable brake operation.
During troubleshooting, check the drive’s brake-output status, relay operation, coil voltage, parameter settings, and STO fault indicators. Consequently, engineers can distinguish a brake-circuit fault from a safety-input problem without bypassing protective functions.
For vertical axes, assess the consequences of power loss and STO activation before selecting the brake arrangement. Moreover, use appropriately engineered mechanical protection where a single holding brake cannot safely prevent a falling load.
Finally, document the wiring, parameter values, test results, and maintenance requirements. Therefore, a carefully validated design improves uptime while keeping personnel protection ahead of convenience.
Frequently Asked Questions About Servo Motor Brake Control
Why Is a Relay Important for Servo Motor Brake Control?
An external relay switches power to the brake coil. It also helps protect the servo drive output from excessive electrical loads. Always check the drive's output rating and the relay manufacturer's instructions before wiring.
How Does a Flyback Diode Support Servo Motor Brake Control?
A relay coil can produce voltage spikes when switched off. A suitable flyback diode helps limit these spikes and protects connected electronics. However, confirm the correct suppression method before installation.
Can STO Replace Servo Motor Brake Control?
No. Safe Torque Off (STO) prevents the drive from generating torque, while a mechanical holding brake secures the shaft. Vertical axes may require both functions to reduce the risk of unexpected movement.
Conclusion
Reliable servo motor brake control requires correct wiring, accurate timing, and proper safety integration. Each component must work together to ensure controlled movement and safe stopping. Therefore, engineers should verify the motor specifications, brake voltage, relay ratings, and drive output limits before commissioning the system.
Furthermore, technicians must configure the brake release and engagement delays according to the manufacturer's instructions. Incorrect timing can cause unexpected movement, excessive mechanical stress, or premature brake wear. Always test the complete sequence during commissioning to confirm that the motor and holding brake operate correctly.
Safe Torque Off (STO) also requires careful consideration. STO prevents the drive from generating torque, but it does not mechanically hold a suspended load or provide electrical isolation. Consequently, vertical applications may need a suitable holding brake and additional protective measures. Engineers must assess the risks and follow the drive manufacturer's safety instructions.
Before placing the system into service, inspect all wiring connections, verify brake operation, and test both STO channels according to the manufacturer's procedure. Document the test results and schedule regular maintenance to identify wear, loose connections, and timing issues.
Ultimately, a well-designed servo motor brake control system improves operational reliability and helps protect personnel, machinery, and production equipment. By combining correct wiring, verified timing, suitable safety measures, and routine inspections, engineers can reduce avoidable faults and maintain safer automation operations.
Pingback: Multi Axis Servo Control: PLC Electronic Gearing Guide